I am a research engineer with broad interests in Robotics and Embodied AI. I graduated from Shanghai Jiao Tong University(上海交通大学, THE 43, QS 45, ARWU 46), advised by Prof. Danping Zou and Prof. Wenxian Yu in SJTU-VISYS Lab. Furthermore, I was a research intern at MIT-IBM Watson Lab under the supervision of Prof. Chuang Gan and participated in SRP2023(Summer Research Programme) at HKU MaRS Lab advised by Prof. Fu Zhang. Previously, I also spent wonderful time researching at Tencent Robotics X Lab, Shanghai AI Lab and Shanghai Beidou Research Institute, where I worked on a variety of projects related to robotics and intelligent systems.
My works have been accepted to top conferences/transactions on Robotics and AI such as CoRL, ICRA, IROS, RAL, CVPR, TRO, TAES and GPS Solutions and so on. My research has been supported by National Key R&D Program and NSFC. My highlighted projects include 🔥M2DGR, 🔥Ground-Fusion, 🔥DAF, 🔥Ground-Fusion++/M3DGR, LIGO, EN-SLAM,Ground-Challenge, Sky-GVINS and so on, as detailed below. Furthermore, I’m also an active open-source contributor, receiving over 3k stars from my Github.


News
- 09.2026 🏆 WM-Craftnet is accepted to CoRL2026 and selected as CoRL Spotlight (Top 4.4%)! [Project]
- 06.2026 🎉 We release Ultra-Fusion, a SOTA SLAM framework on wheeled/legged/aerial robots and autonomous cars! [Code]
- 06.2026 NIDAR is accepted to IROS2026!
- 02.2026 In-P3VIO is accepted to TAES2026!
- 06.2025 LIGO is successfully transfered to IROS2025!
- 06.2025 Ground-Fusion++/M3DGR isaccepted to IROS2025!
- 01.2025 🏆 M2DGR is awarded ESI Highly Cited Paper (Top 1%)!
- 01.2025 LIGO is accepted to TRO2025!
- 06.2024 DAF is accepted to IROS2024!
- 03.2024 Ground-Fusion is accepted to ICRA2024!
- 03.2024 🏆 EN-SLAM is accepted to CVPR2024 and selected as CVPR Highlight (Top 2.6%)!
- 03.2024 A paper is accepted to GPS Solutions!
- 08.2023 M2C-GVIO is accepted to Satellite Navigation!
- 06.2023 I won the HKU Summer Research Programme Scholarship!
- 12.2021 M2DGR is accepted to RAL and ICRA2022!
⭐️ Selected Research
🚩 Publication
Currently, I focus on reinforcement learning, dexterous manipulation and whole-body control. My research goal is to build practical intelligent robots that can safely and reliably operate in real human environments, assisting people with everyday physical tasks. Previously, I worked on multi-sensor fusion SLAM algorithms/benchmarks under corner cases and multimodal navigation. (Representative works are highlighted)
 | WM-Craftnet: World Synesthesia Model for Generalizable and Robust Dexterous In-Hand Manipulation (CoRL Spotlight (Top 4.4%)) Representative Work CoRL 2026 |

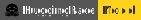
 | NIDAR: NIR-Guided Intrinsic Decomposition for Scalable Scene-Agnostic LiDAR Intensity Reconstruction IROS 2026 (Oral) |
 | Ultra-Fusion: A Resilient Tightly-Coupled Multi-Sensor Fusion SLAM Framework under Sensor Degradation and Spatiotemporal Perturbation for Intelligent Transportation Systems Representative Work arXiv preprint 2026 |


 | In-P3 VIO: Tightly-Coupled PPP-Visual-Inertial Odometry Based on Invariant Filter Approach IEEE Transactions on Aerospace and Electronic Systems 2026 |
 | Towards Robust Sensor-Fusion Ground SLAM: A Comprehensive Benchmark and A Resilient Framework IROS 2025 (Oral) |

 | LIGO: A Tightly Coupled LiDAR-Inertial-GNSS Odometry Based on a Hierarchy Fusion Framework for Global Localization With Real-Time Mapping TRO 2025 & IROS 2025 (Oral Presentation) |

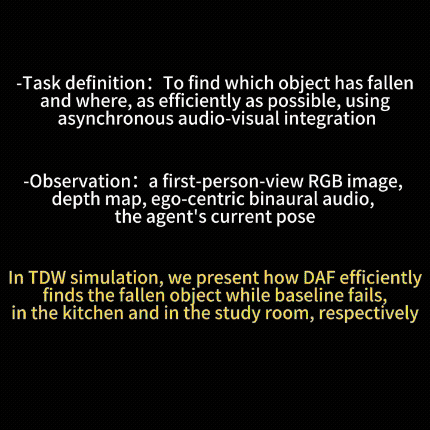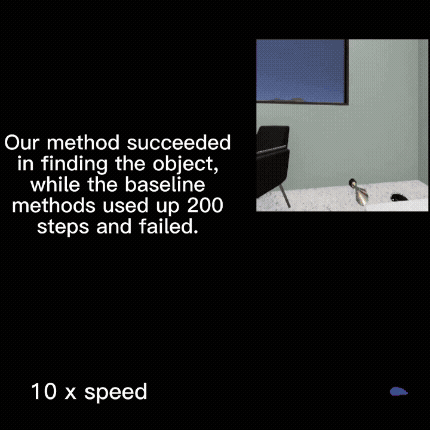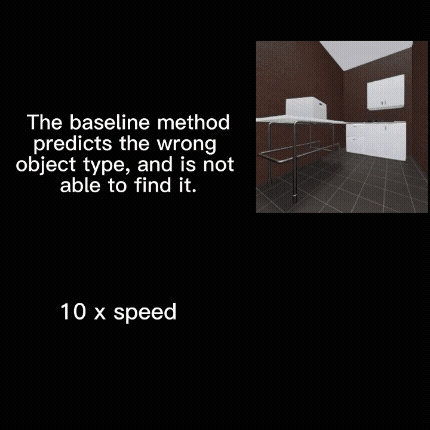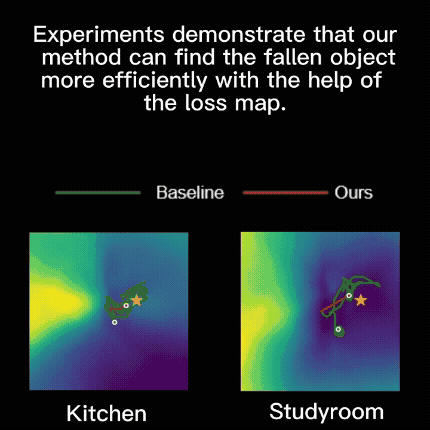
 | Disentangled Acoustic Fields For Multimodal Physical Scene Understanding Representative Work IROS 2024 (Oral) |


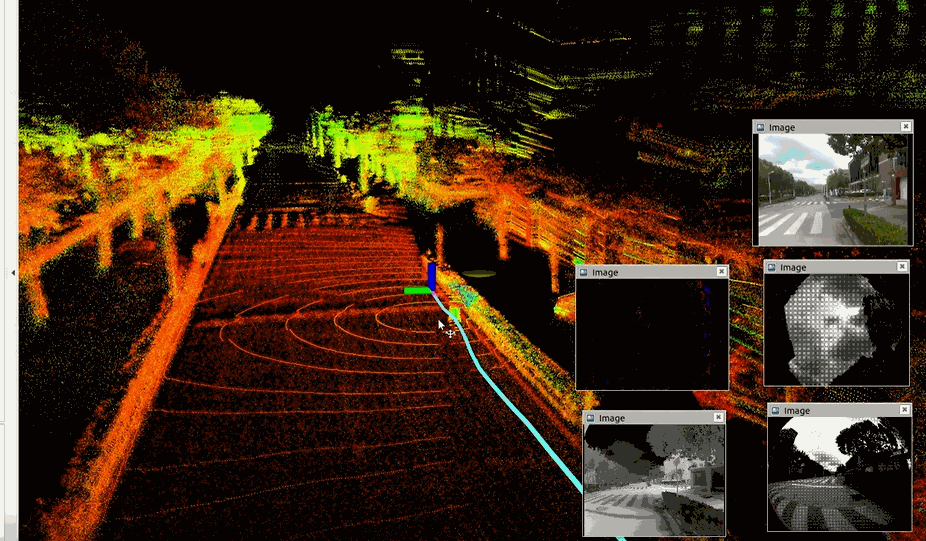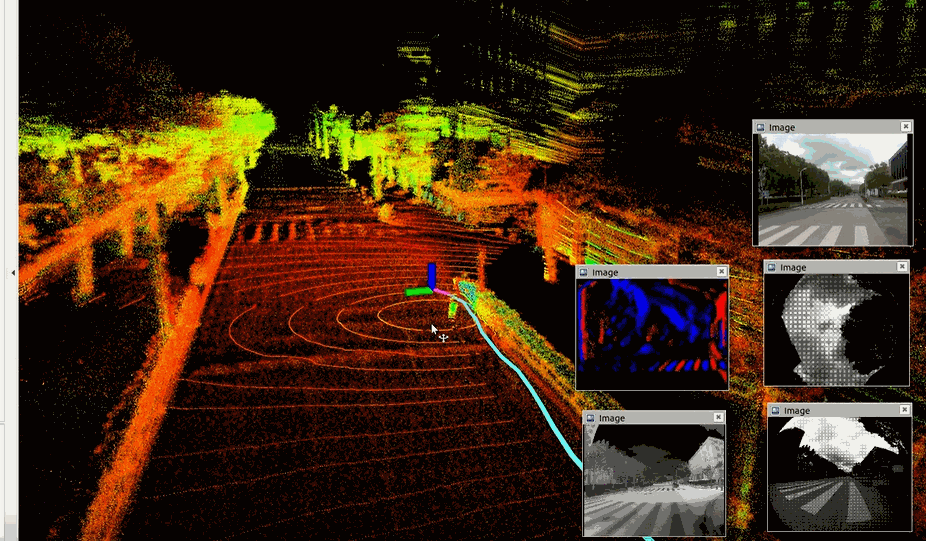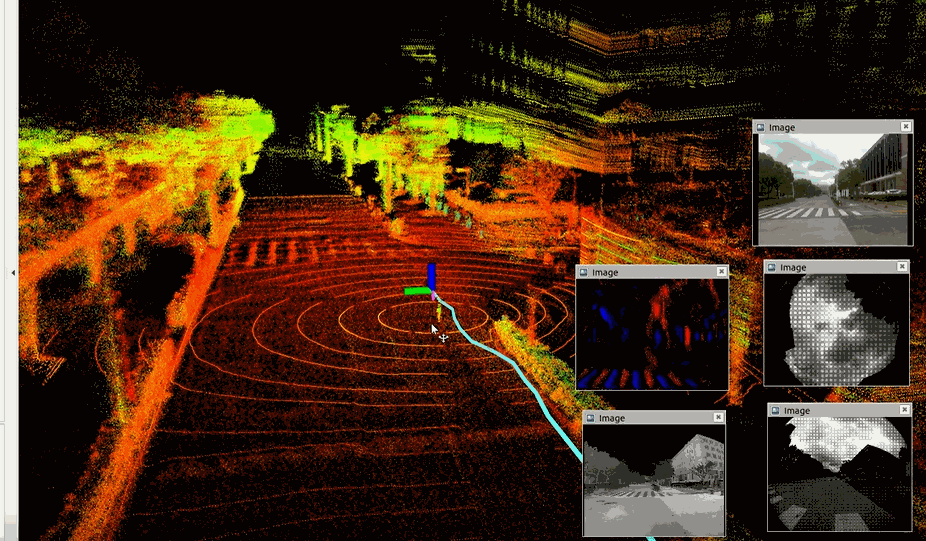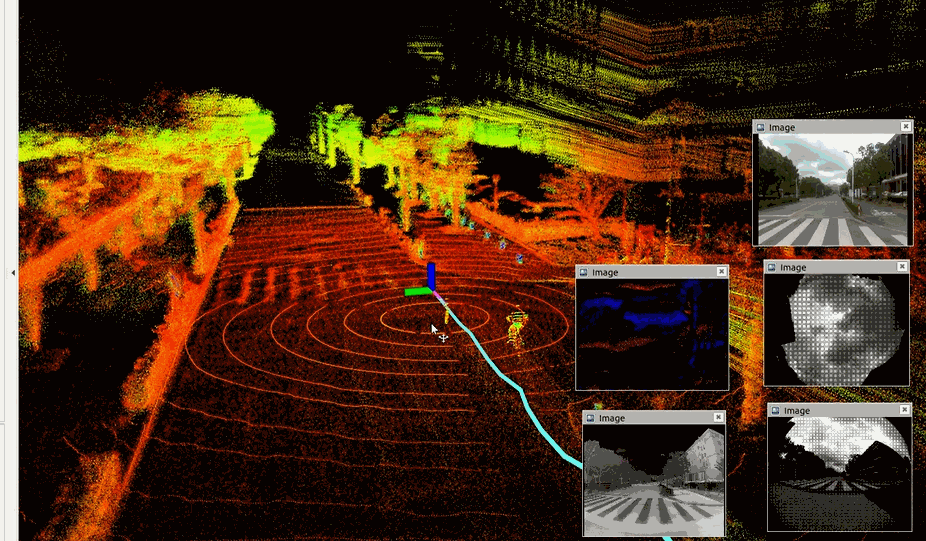
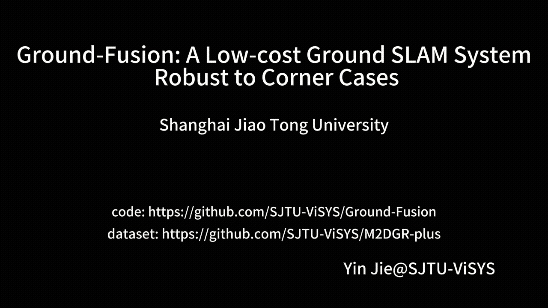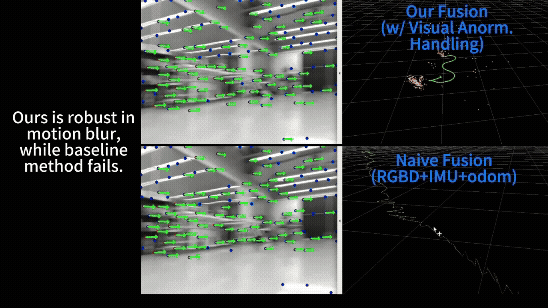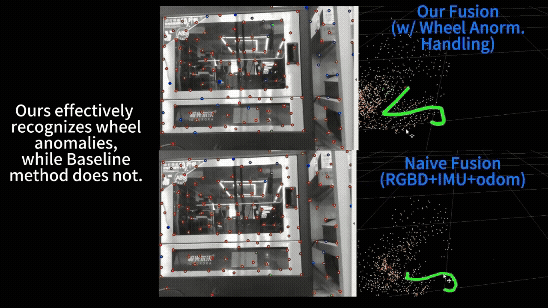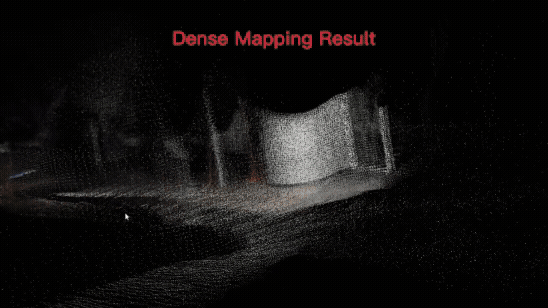
 | Ground-Fusion: A Low-cost Ground SLAM System Robust to Corner Cases Representative Work ICRA 2024 (Oral) |


 | Implicit Event-RGBD Neural SLAM (CVPR Highlight (Top 2.6%)) CVPR 2024 |

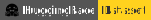
 | Innovation-based Kalman filter fault detection and exclusion method against all-source faults for tightly coupled GNSS/INS/Vision integration |
 | Sky-GVINS: a Sky-segmentation Aided GNSS-Visual-Inertial System for Robust Navigation in Urban Canyons Geo-spatial Information Science (JCR Q1) 2023 |

 | M2C-GVIO: motion manifold constraint aided GNSS-visual-inertial odometry for ground vehicles |
 | M2DGR: A Multi-Sensor and Multi-Scenario SLAM Dataset for Ground Robots(ESI Highly Cited Paper, Top 1%) Representative Work RA-L 2021 & ICRA 2022 (Oral Presentation) |

Projects
 | Design, Sensing and Control of Service Robotic System for Intelligent Navigation and Operation in Internet Data Centers (Reddot Design Award2022) IEEE CASE 2022 |
 | Ground-Challenge: A Multi-sensor SLAM Dataset Focusing on Corner Cases for Ground Robots |

 | A GNSS-Visual-IMU benchmark Dataset for SLAM Github 2022 |

Academic Service
- Conference reviewer for ICRA(2023-now) , IROS (2023-now) , CoRL(2026-now) and RSS(2026-now).
- Transaction reviewer for RA-L (2022-now), TRO (2024-now), TASE (2024-now) and IJRR (2026-now).
Honors
- HKU Summer Research Programme (SRP) Scholarship, 2023 — Selected from 92 / 1,000+ global applicants · Top ~9%
- Academic Scholarship, SJTU — Awarded in 2018, 2020, 2022 & 2023
- Outstanding Graduate, SJTU, 2021 — Top 15%
- National Third Prize, National English Competition for College Students (NECCS), 2018 — Top 5% among 1.2M+ participants nationwide
- CET-6: 634 / 710, Dec 2018 — Top ~2% among ~3.2M test-takers nationwide
Teaching
- Teaching assistant for Visual Localization & Perception (EE382) in SJTU.
- Course tutor on SLAM in CVLIFE.